Ukemi-SafeFall
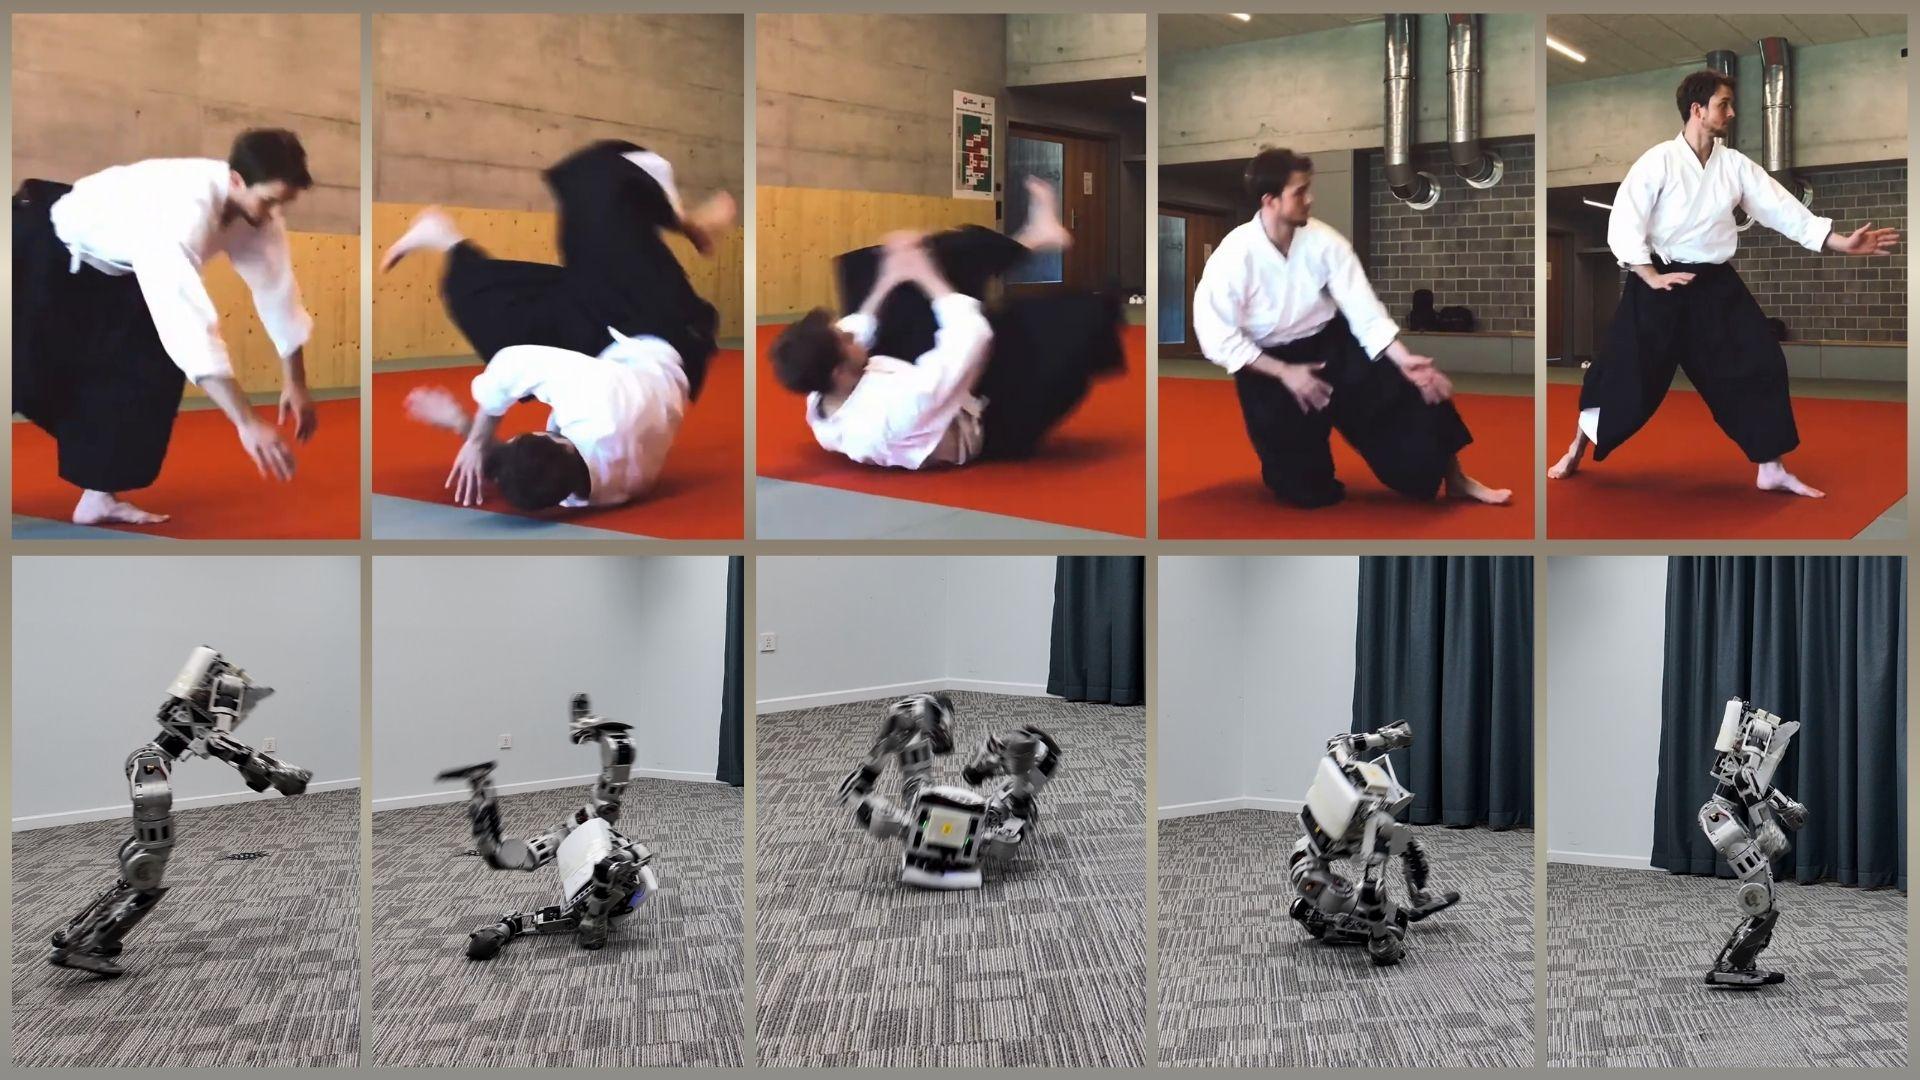
Teaching a humanoid robot to fall like a martial artist: rolling to soften the impact, then getting back up on its own.
Founding Engineer @ Robotensor
I build robots and learning-based systems.
My work spans robot learning, locomotion, embedded systems, and hardware, especially systems that have to work on real robots.
Teaching a humanoid robot to fall like a martial artist: rolling to soften the impact, then getting back up on its own.
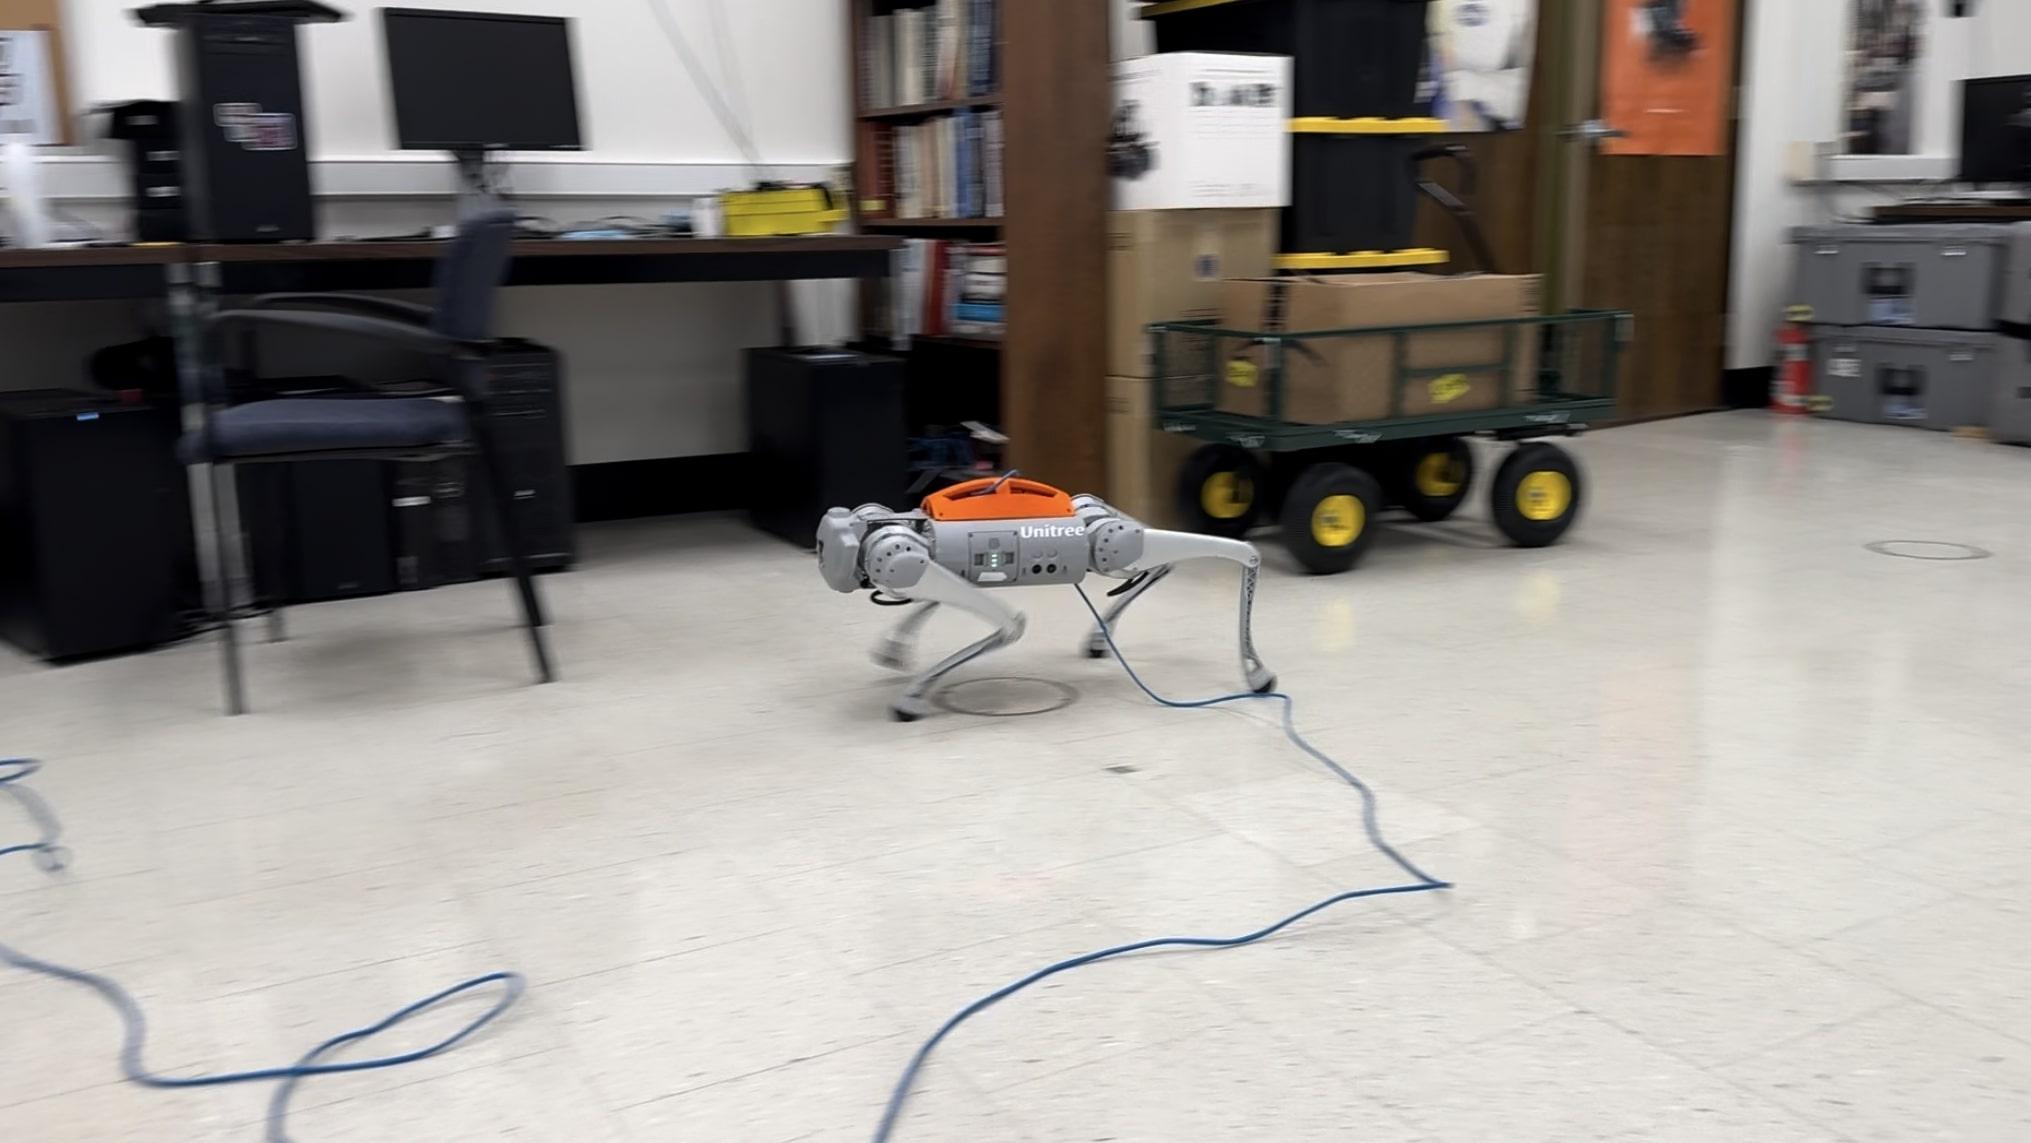
Walking policies trained in simulation across different terrain, then deployed on a real Unitree Go1.
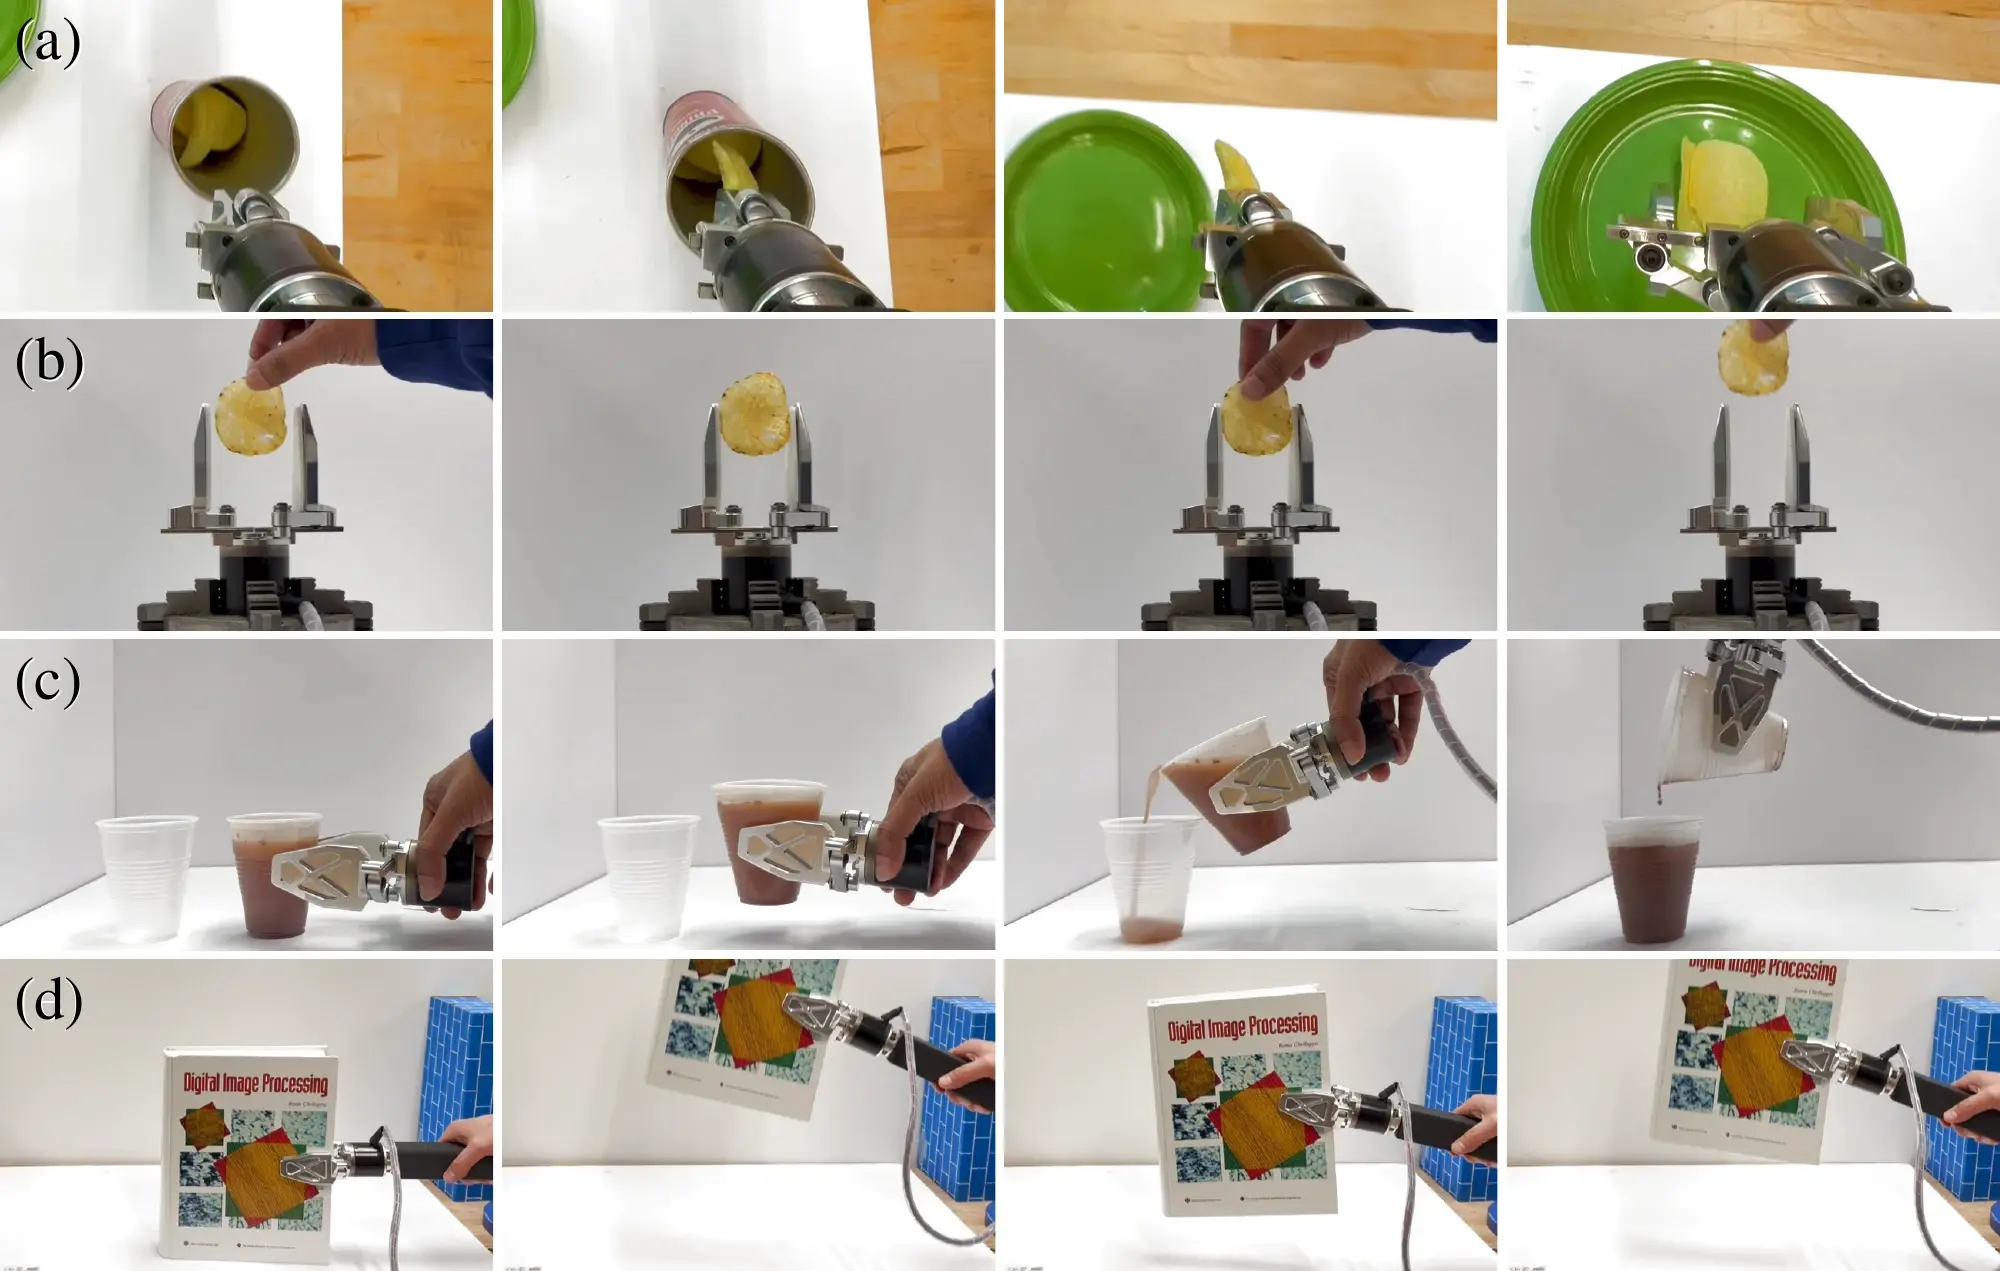
A compact robotic gripper designed to handle both fragile and heavy objects while remaining highly backdrivable.
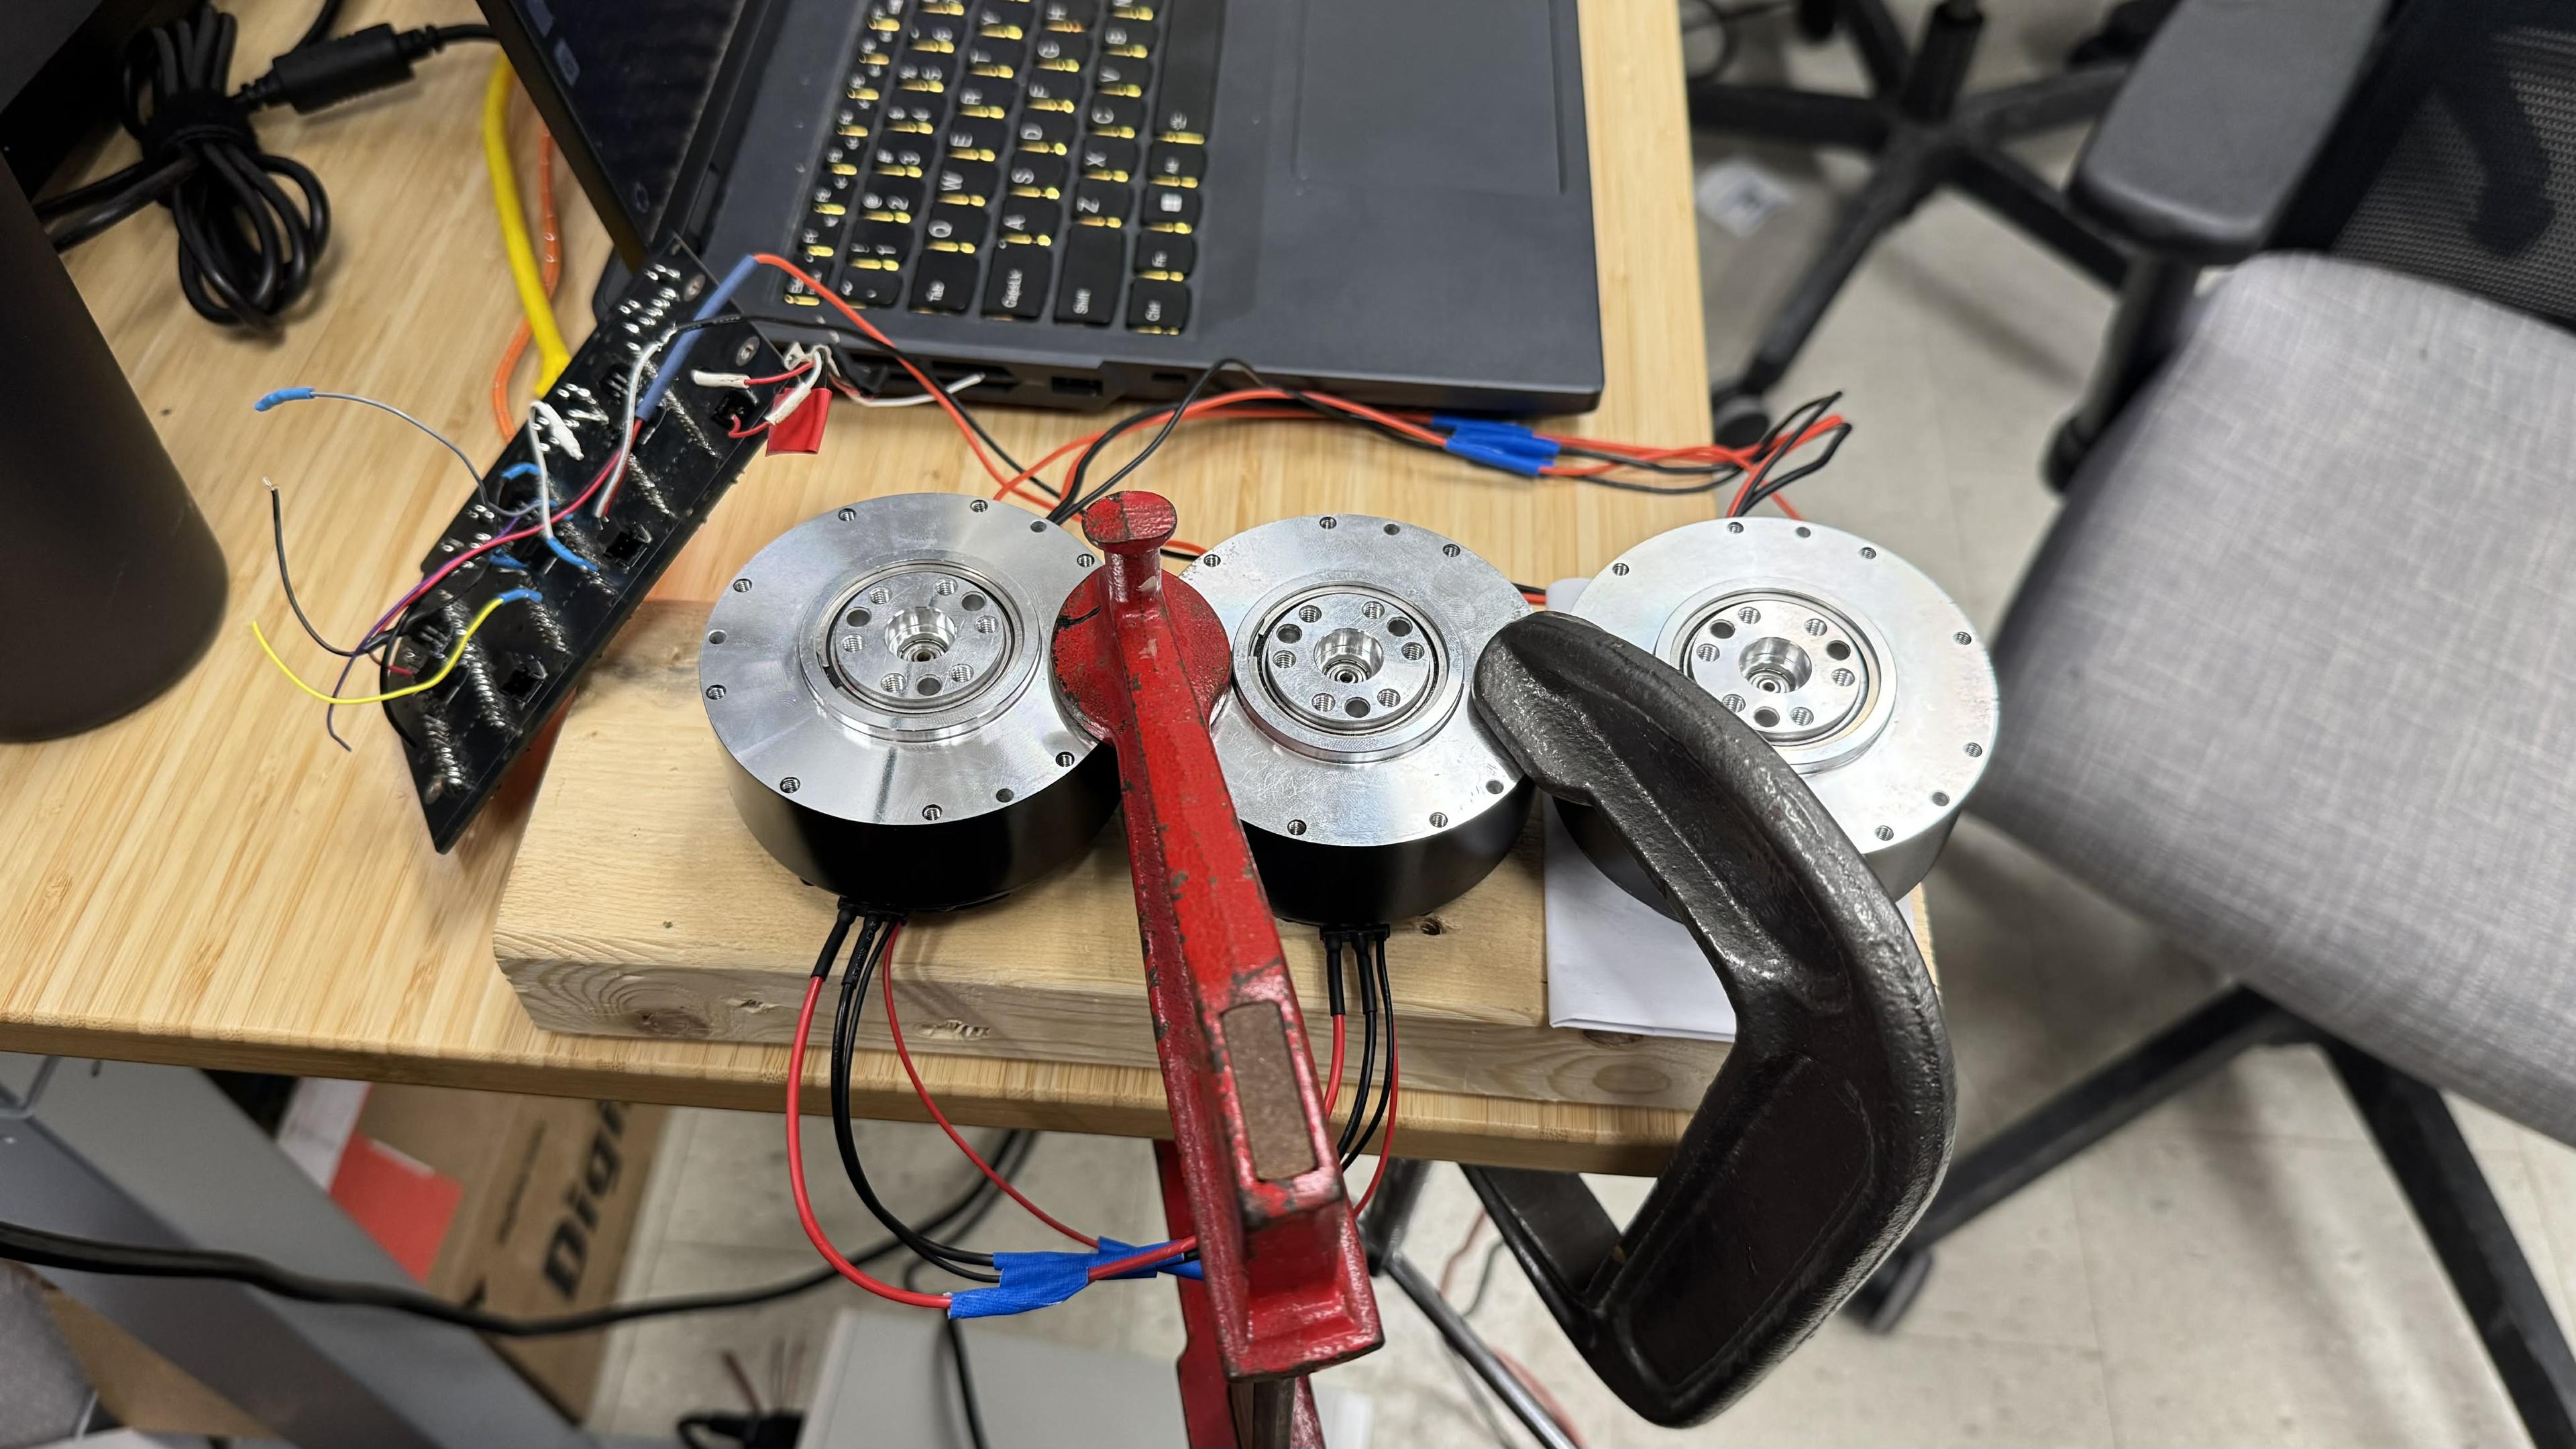
A hardware and software bridge that lets a PC reliably control multiple robot motors over Ethernet.
My projects have increasingly pulled me toward two questions.
Ukemi-SafeFall is one answer so far: a humanoid that learns to roll out of a fall and get back up.
See the project →Robots that students can understand, repair, modify, and keep building on.
Explore educational robots →Ukemi-SafeFall: An Ukemi-inspired Injury-Aware Falling and Recovery
IEEE-RAS International Conference on Humanoid Robots (Humanoids) · Accepted, to be presented · Co-first author
ForteGrip: A Compact, High-Force, Backdrivable Parallel Gripper
IEEE International Conference on Robotics and Automation (ICRA) · Under review · Co-author
IEEE World AI IoT Congress (AIIoT)
Master of Science in Computer Science
University of Massachusetts Amherst, USA
Erasmus+ Exchange Scholarship in Mechatronics Engineering
University of Limerick, Ireland
Bachelor of Engineering in Mechatronics Engineering
Ho Chi Minh City University of Technology, Vietnam National University, Vietnam
Places I've lived, studied and traveled.